2x2 网格,16:9,AI 选题:I(0) = 空白哑光背景。I(1) = $ DESTINATION(目的地)的最终等距微缩模型…
分享链接 · https://openimages.ajiang.me/p/2091956203865755691/
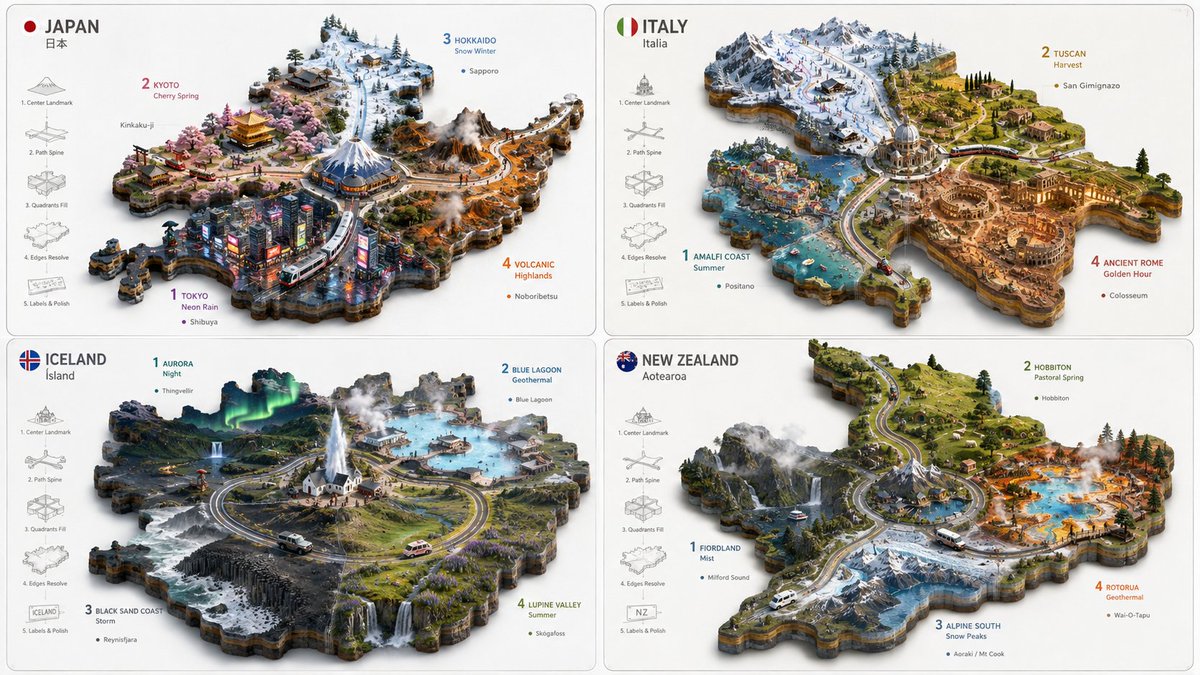
camera_lens · isometriccamera_lens · orthographiccolor_palette · vibrantcomposition · multi-panellighting · soft-lightquality_flags · embedded-text
提示词(原文,逐字保留)
2x2 grid, 16:9, AI picks topics: I(0) = blank matte background. I(1) = final isometric miniature of $ DESTINATION, its landmass cut as silhouette $ SHAPE and floating as a diorama partitioned into four wedges — $ STATE_1, $ STATE_2, $ STATE_3, $ STATE_4 — with ONE continuous $ PATH flowing unbroken through all four. ∂I/∂t = Δ(I, $ DESTINATION, $ SHAPE) under a piecewise state field S(θ) that rotates through the four quadrants. Constraints: isometric projection, base-shape adherence, center-outward build order, seamless path continuity across seams, four distinct palettes/weathers meeting cleanly at the center, cross-section side walls, soft global illumination. Integration: t=0.0–0.15: faint isometric base outline in silhouette $ SHAPE, quadrant seams and a light guide grid appear. t=0.15–0.4: the central hub landmark of $ DESTINATION rises first where all four wedges meet; the $ PATH's spine blocks in. t=0.4–0.7: each quadrant fills outward in its own state — foliage, weather, lighting and tiny figures shifting per wedge — while the $ PATH threads a little traveler/vehicle through the transitions. t=0.7–0.9: edges resolve into a clean cross-section revealing strata; each wedge's outer props finalize the silhouette. t=0.9–1.0: soft shadows, small labels for each state and stop appear, global illumination settles, final polish. Output I(1) as an 8K isometric four-state journey diorama masterwork.
中文译文
2x2 网格,16:9,AI 选题:I(0) = 空白哑光背景。I(1) = $ DESTINATION(目的地)的最终等距微缩模型,其陆地按 $ SHAPE(轮廓形状)裁切并漂浮成一个分为四个楔形区块的立体模型 —— $ STATE_1、$ STATE_2、$ STATE_3、$ STATE_4 —— 其中有一条连续的 $ PATH(路径)不断裂地贯穿全部四个区块。∂I/∂t = Δ(I, $ DESTINATION, $ SHAPE),在分段状态场 S(θ) 之下,状态场在四个象限之间轮转。约束条件:等距投影、严格贴合基础形状、由中心向外的构建顺序、跨接缝的无缝路径连续性、四种不同的色调/天气在中心整齐交汇、横截面侧壁、柔和全局光照。分阶段过程:t=0.0–0.15:出现淡淡的等距基础轮廓,呈 $ SHAPE 剪影,呈现象限接缝与轻量引导网格。t=0.15–0.4:$ DESTINATION 的中心枢纽地标率先在四个楔形交汇处升起;$ PATH 的主干定型。t=0.4–0.7:每个象限以各自状态向外延展 —— 植被、天气、光照与微小人物随楔形而变 —— 同时 $ PATH 让一位小旅人/小车穿行于各状态之间。t=0.7–0.9:边缘收束为整洁的横截面,显露地层;各楔形外侧道具定型整体剪影。t=0.9–1.0:柔和阴影出现,为每个状态与停靠点加上小标签,全局光照定型,最终润色。输出 I(1) 为一张 8K 等距四态旅程立体模型杰作。
来源与署名
原文由 @Gdgtify 发布在 X:查看原推文。 本页逐字保留原文并提供机器翻译的中文解读;版权归原作者所有。
同工具的更多提示词
- 高级极简扁平矢量旅行海报,[alburimi oman],3:4 竖版。 创作一幅独特的城市专属旅行海报,捕捉 [CITY_NAME] 的真实个性。根据城市特…@Q_Alzeidi
- GPT image 2 提示词(ChatGPT 平台) 提示词 👇 高端极简扁平矢量旅行海报,[CITY_NAME] 主题,3:4 竖版格式。 请创作一幅原创…@KrishnaBio1
- 中近景肖像,一位年轻南亚女性,深棕色长发有质感地披在肩上。她身穿简约的黑色长袖上衣,微微转身对镜头温柔微笑。背景是温馨、暖光照明 的室内空间,包括一盏柔和发光…@juliaevee
- 高度渲染的漫画/动漫解剖结构,锐利如墨的轮廓线条,密集的交叉影线,手绘赛璐珞上色,以及金属高光。奢侈配饰,强烈定向的漫画式打光配明亮暖色高光,街机格斗游戏主视…@LANDCASTER_92
- 《星际牛仔》中的史派克·斯派格尔,夜晚站在一条肮脏潮湿的小巷中,倚靠着一根生锈的管道。角色有着凌乱的深绿色头发、削瘦的脸庞,带着无聊的表情,嘴里叼着一根香烟…@im_shahid7
- 2x2 网格,对奥运体育项目执行此操作:16:9 INPUT ::= [TOPIC_OR_WORD] W := derive_word(INPUT) A :=…@Gdgtify